Self-Balancing Bot
A two-wheeled robot built to explore real-time balance control and wireless driving.
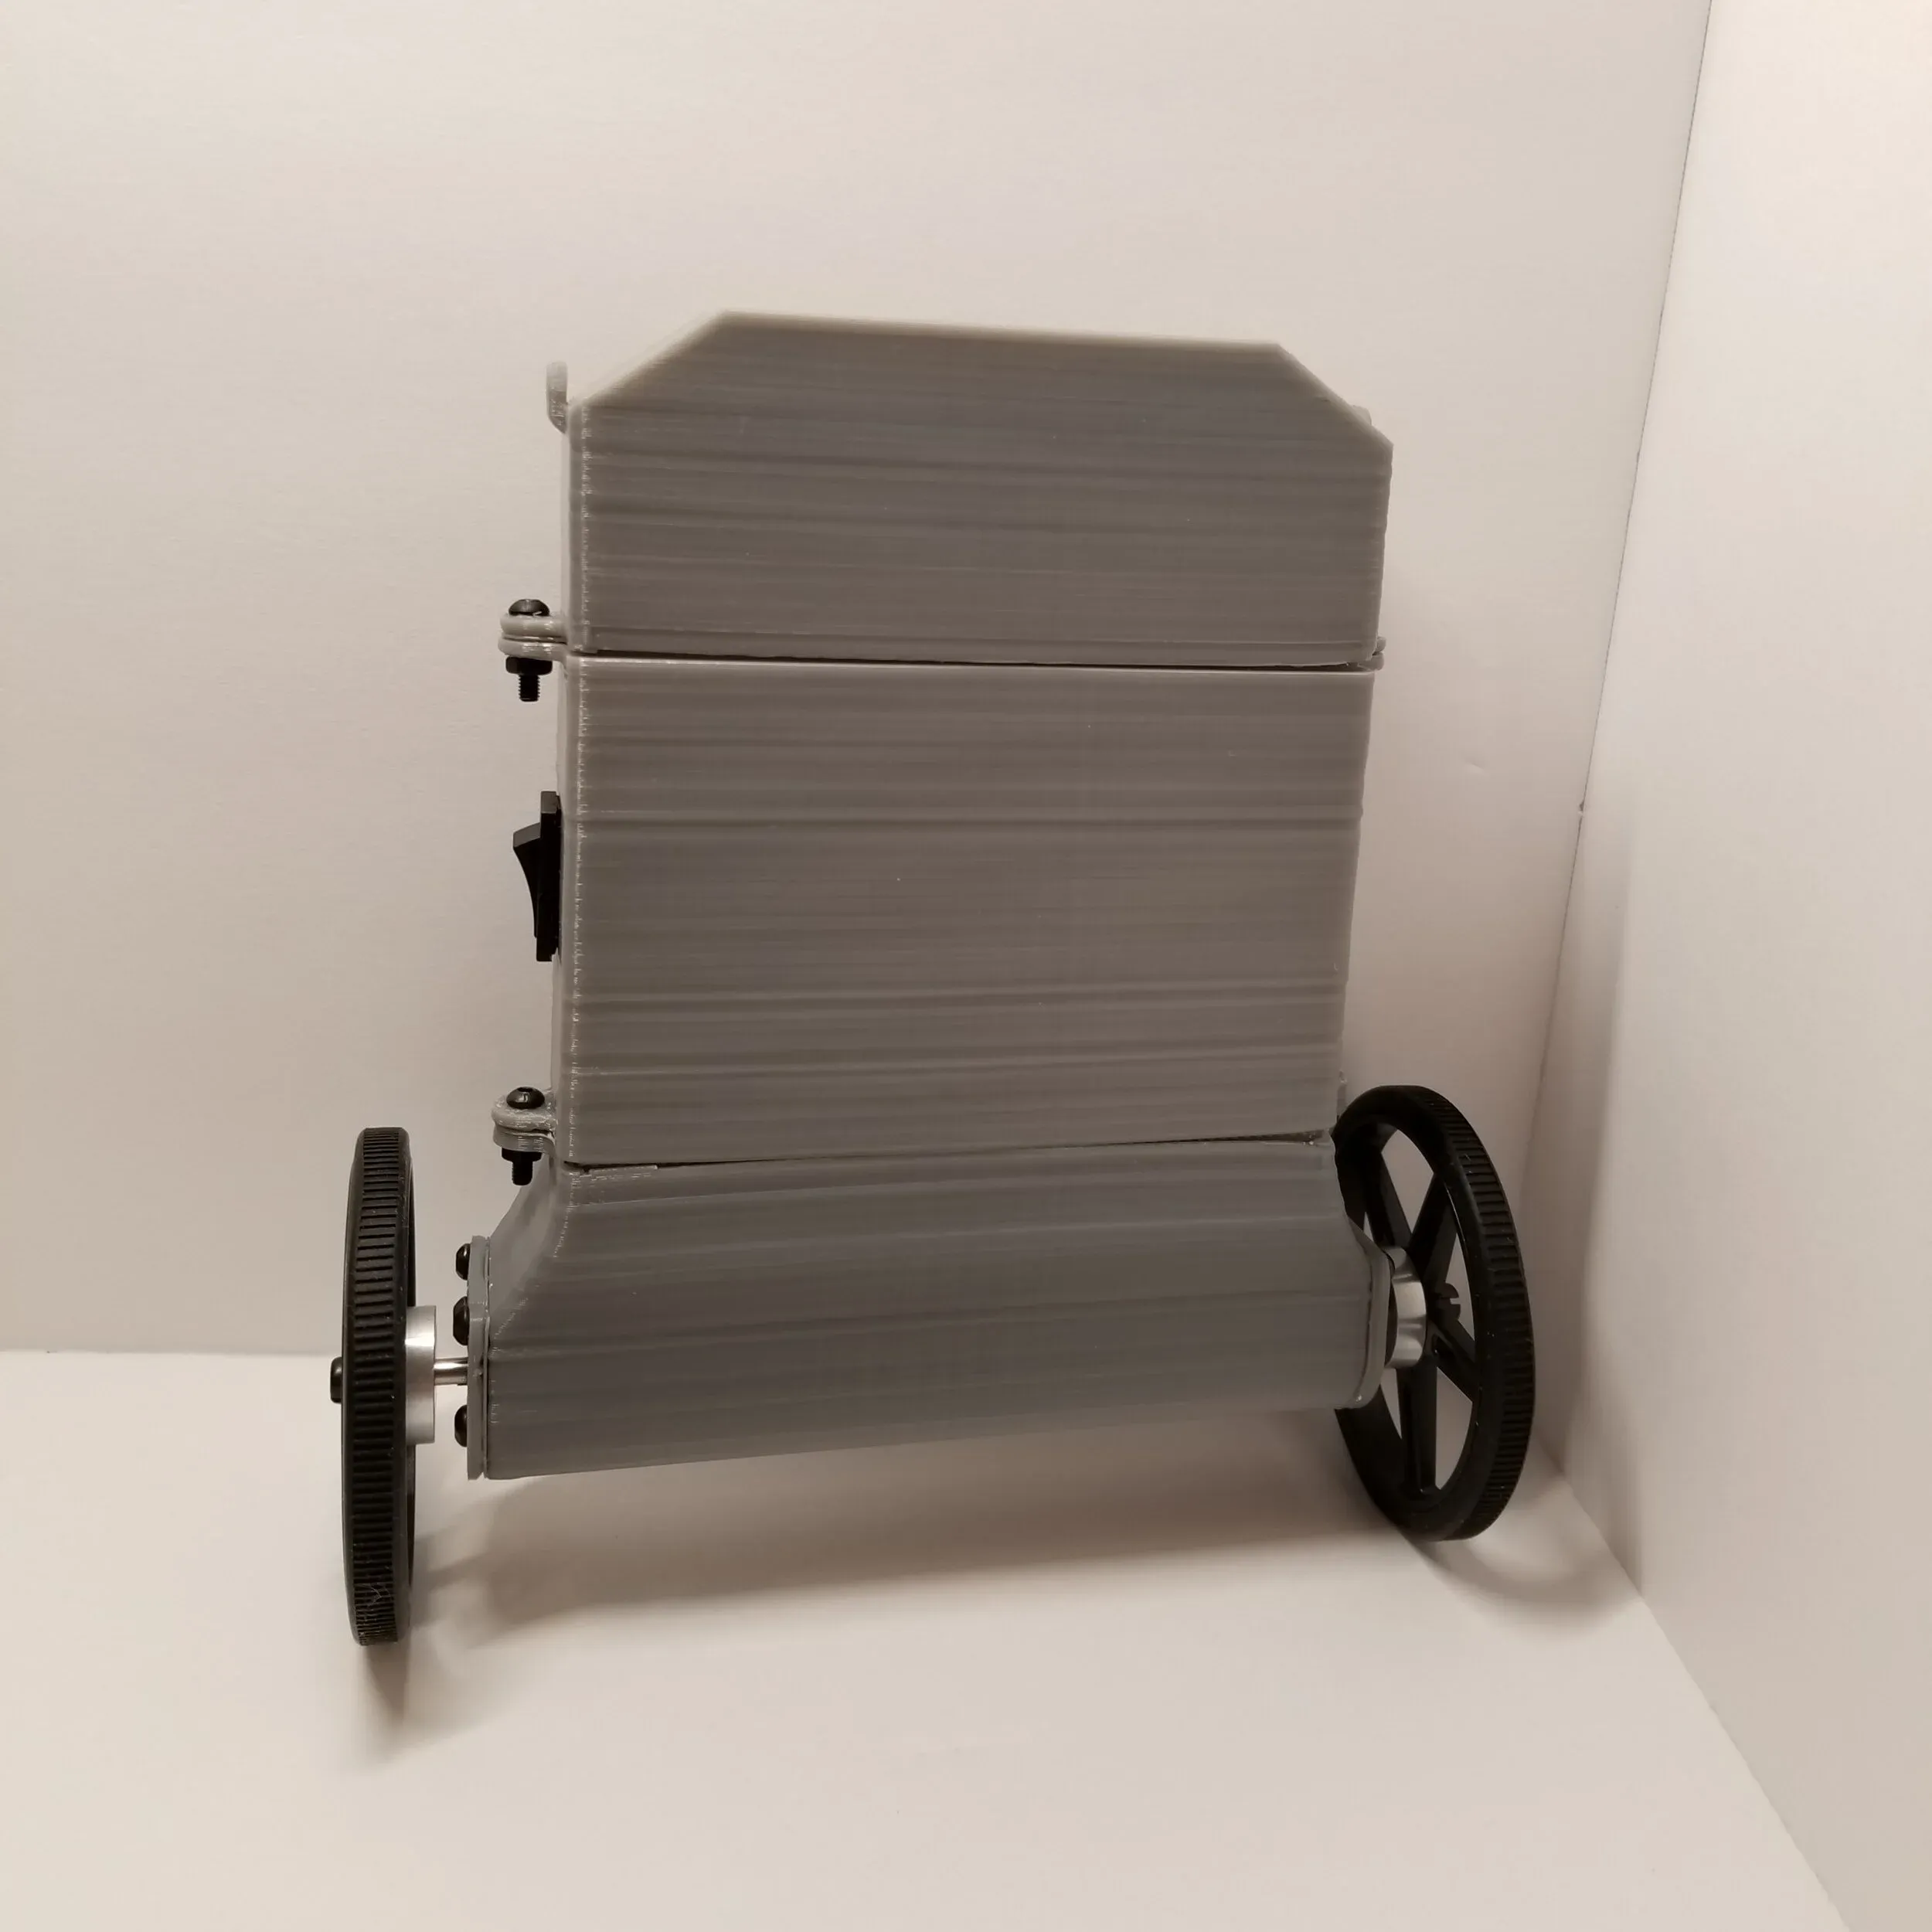
Overview
I built a two-wheeled self-balancing robot to explore proportional-integral-derivative (PID) control on a low-cost physical platform. Balancing an inverted pendulum requires the controller to estimate the robot’s tilt and continually adjust motor output.
Approach
An Arduino-based controller reads an MPU-6050 gyroscope and accelerometer for orientation feedback and drives two geared brushed DC motors. The custom 3D-printed PLA chassis encloses the electronics, motors, and battery. Motor encoders were included as an optional additional feedback source.
I also modified a Wii Nunchuck with an Arduino Micro and Bluetooth module to make a self-contained wireless controller for steering the robot while it balances. The design target was a parts cost below $150.
Results
The completed build brought balance control and wireless driving together in one compact test platform.