JetsonBot
A modular indoor robot built to explore perception and navigation with onboard GPU computing.
Overview
I built JetsonBot to explore robotics and machine-learning ideas on a physical platform instead of limiting experiments to simulations or cloud software. I wanted an indoor robot that was small enough to work with easily, inexpensive enough to modify, and powerful enough to process sensor data onboard.
Approach
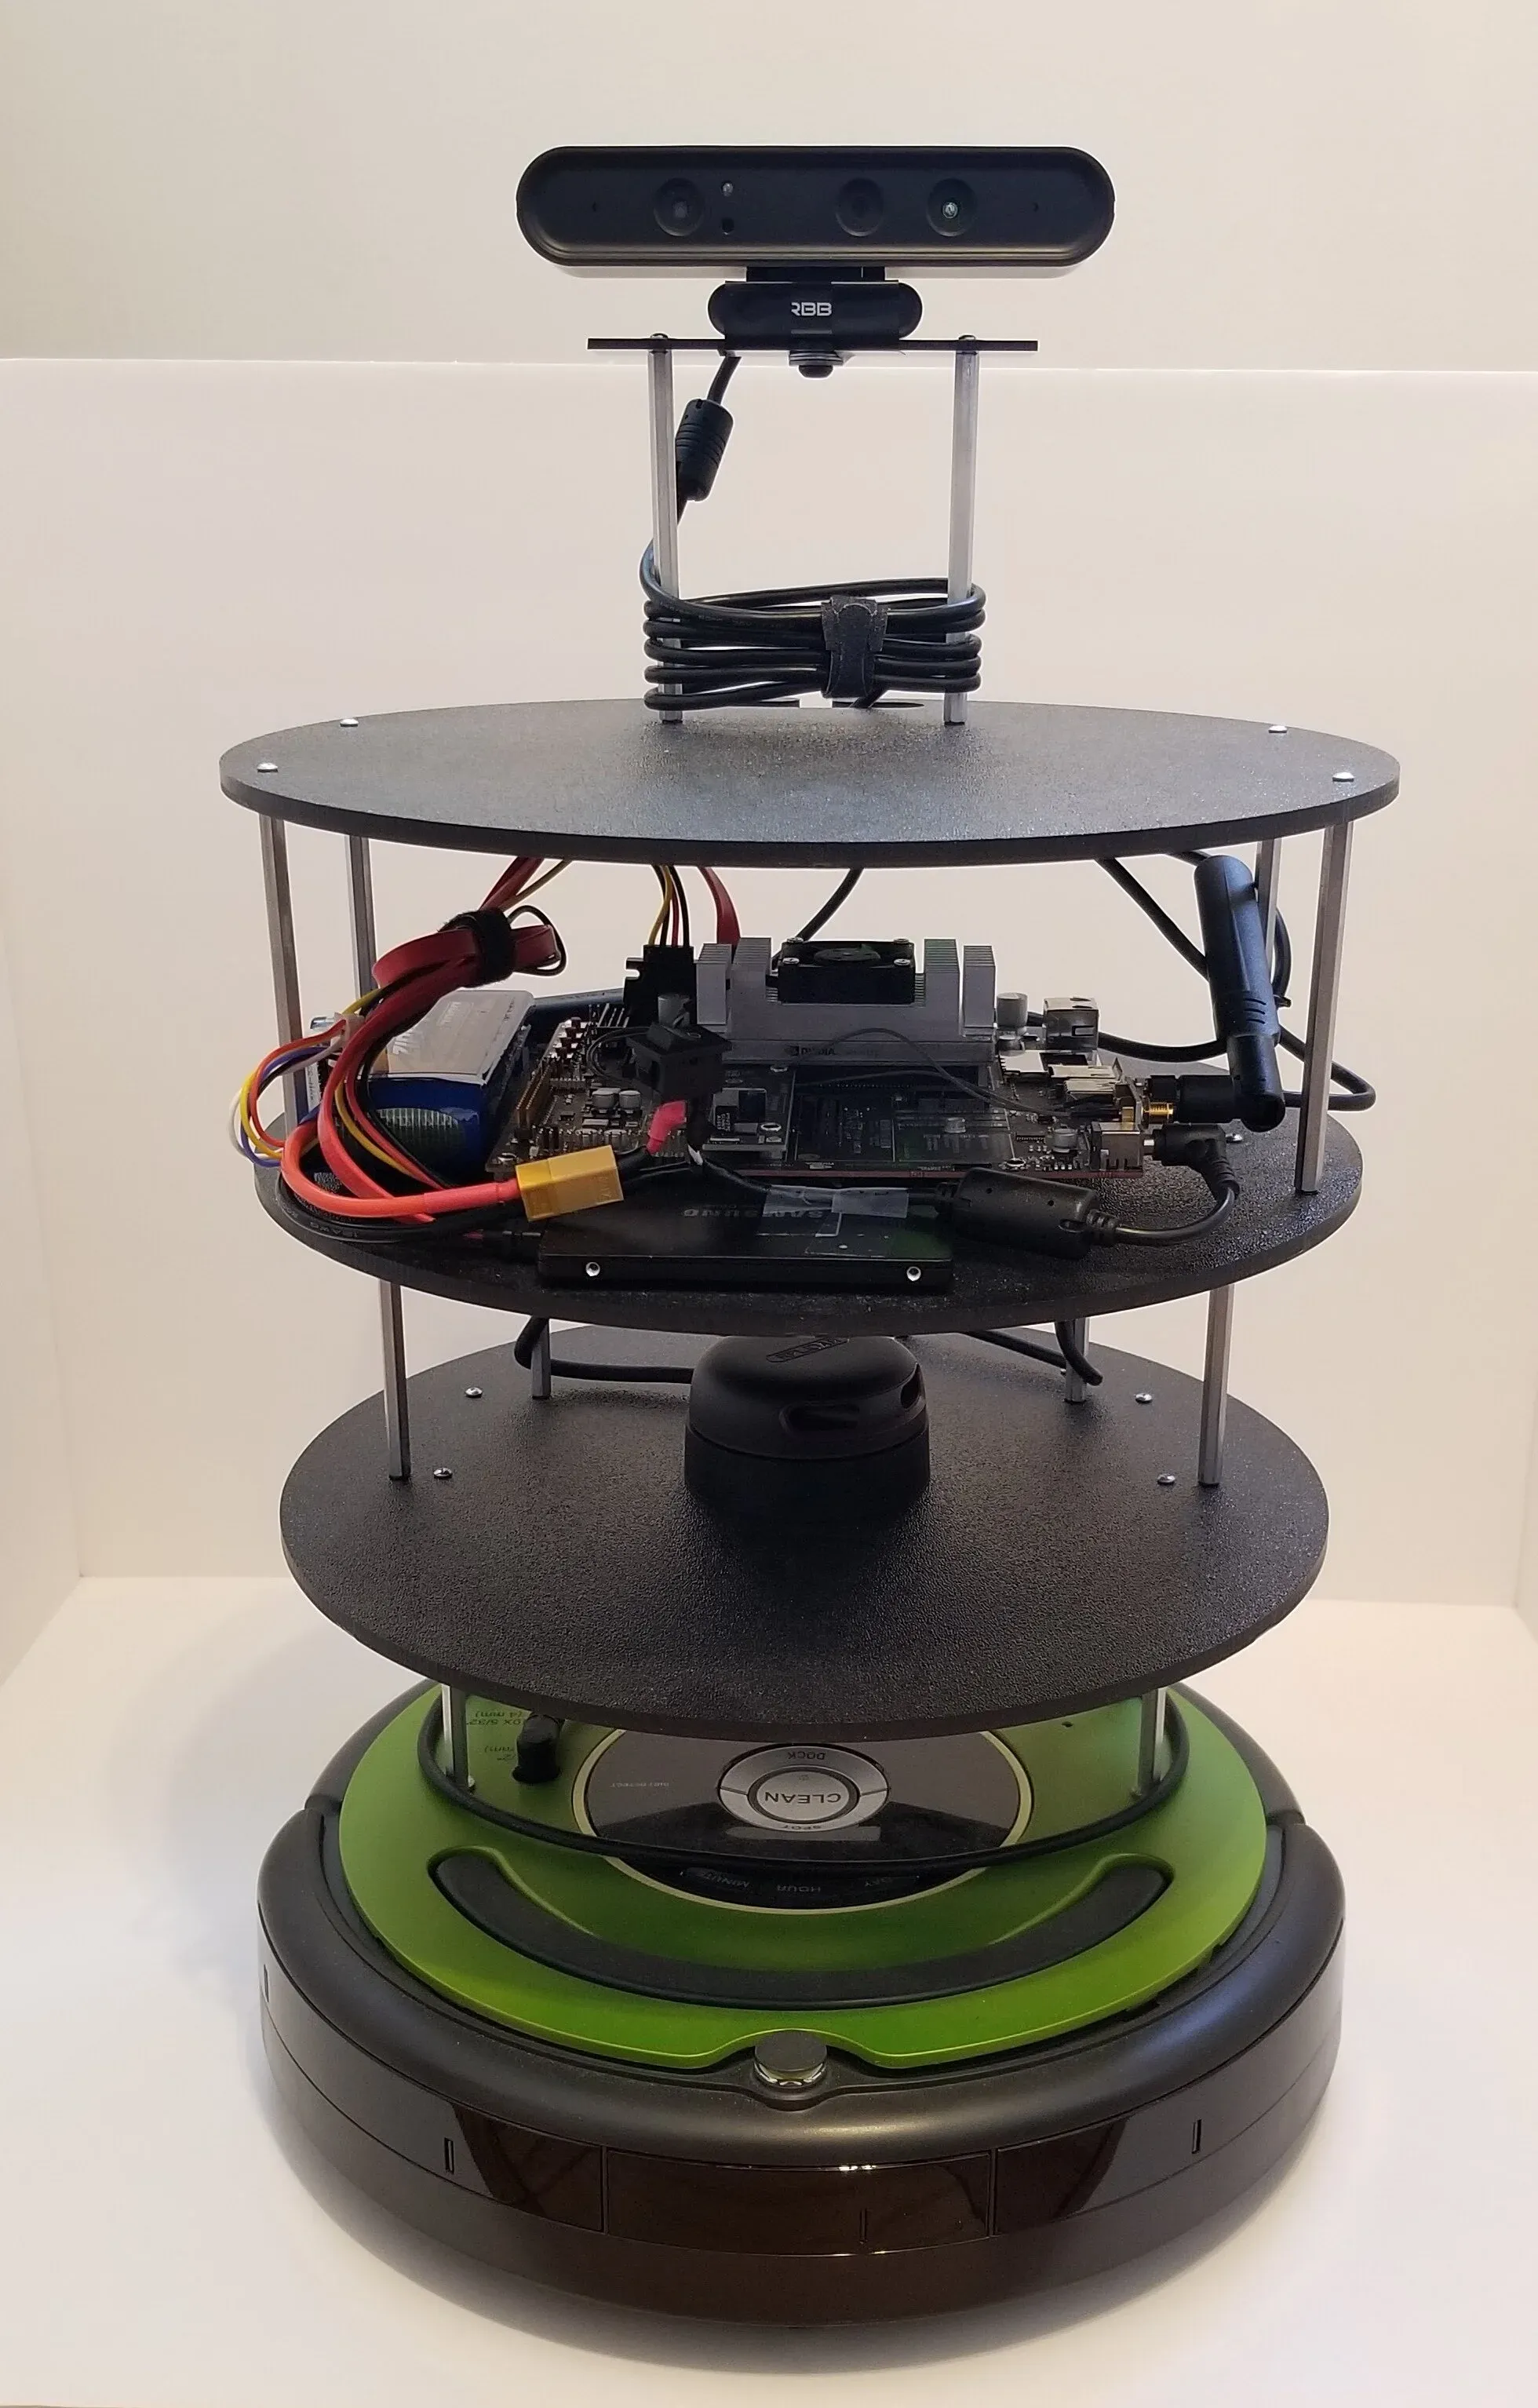
An iRobot Create base supplies the drive system along with bump and cliff sensors. I added an NVIDIA Jetson TX1 as the main computer, giving the robot both CPU and GPU resources for local perception and machine-learning workloads. An RPLIDAR supplies range measurements, while an Orbbec infrared depth camera adds three-dimensional scene information. Together, these sensors provide a starting point for obstacle detection, mapping, and vision-based experiments.
I arranged the hardware on stacked plastic platforms so I could add or replace sensors and attach task-specific hardware without rebuilding the mobile base.
Results
The completed robot combines mobility, range and depth sensing, and onboard GPU computing in one expandable platform. It provides a physical base for future experiments in object recognition, localization, navigation, and human-robot interaction.